AS
New York City · Open to research & engineering roles

Agustina Selser

Biomedical Engineer · Brain-computer interfaces, neuroengineering & robotics.

I build systems that read, decode and respond to signals from the body, from neural interfaces to walking robots.

Selected work

From neural signals to walking hardware to agents that ship code.
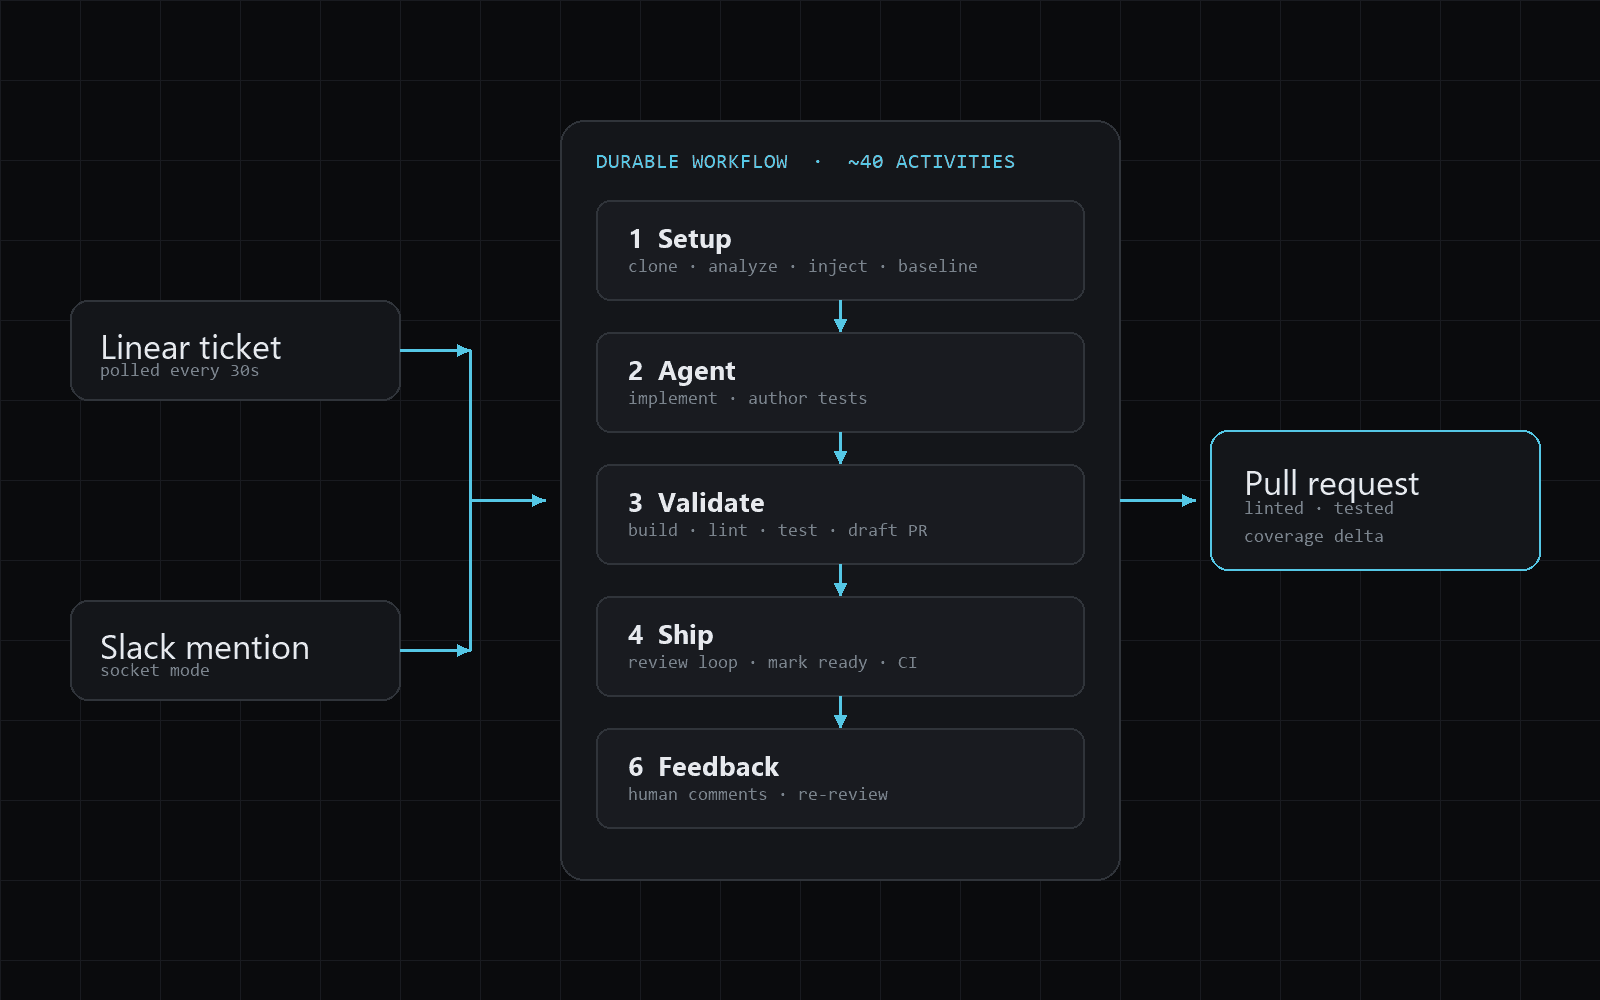
Diagram of the pipeline: ticket sources feeding a durable workflow that produces a pull request

Autonomous Coding Agent

An autonomous coding agent that turns tickets into pull requests

A Go service that takes a Linear ticket or a Slack mention, runs a coding agent against the repository inside a durable workflow, and returns a pull request already built, linted, tested, reviewed and pushed through CI. Seven model families behind one interface. In its best stretches it ranked among the company's top three contributors by merged lines of code.

GoLLM AgentsRAGTemporalKubernetesDockerMCPPlaywrightCI/CDObservability
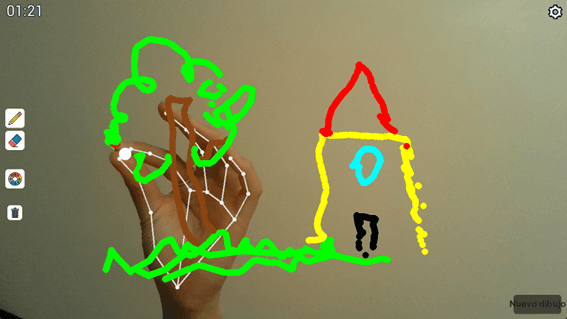
Free Drawing exercise: drawing in the air with a pinch gesture

Hand Rehabilitation Platform

Therapy exercises you play with your hand, and a webcam

My final project: seven exercise games driven by webcam hand tracking, six clinical movements calibrated to each patient's range of motion, and a clinician application for prescribing routines and reading the results back. One of the exercises is playable on this page.

MediaPipeComputer VisionPythonOpenCVPygamePyQt5TypeScriptMedical Devices
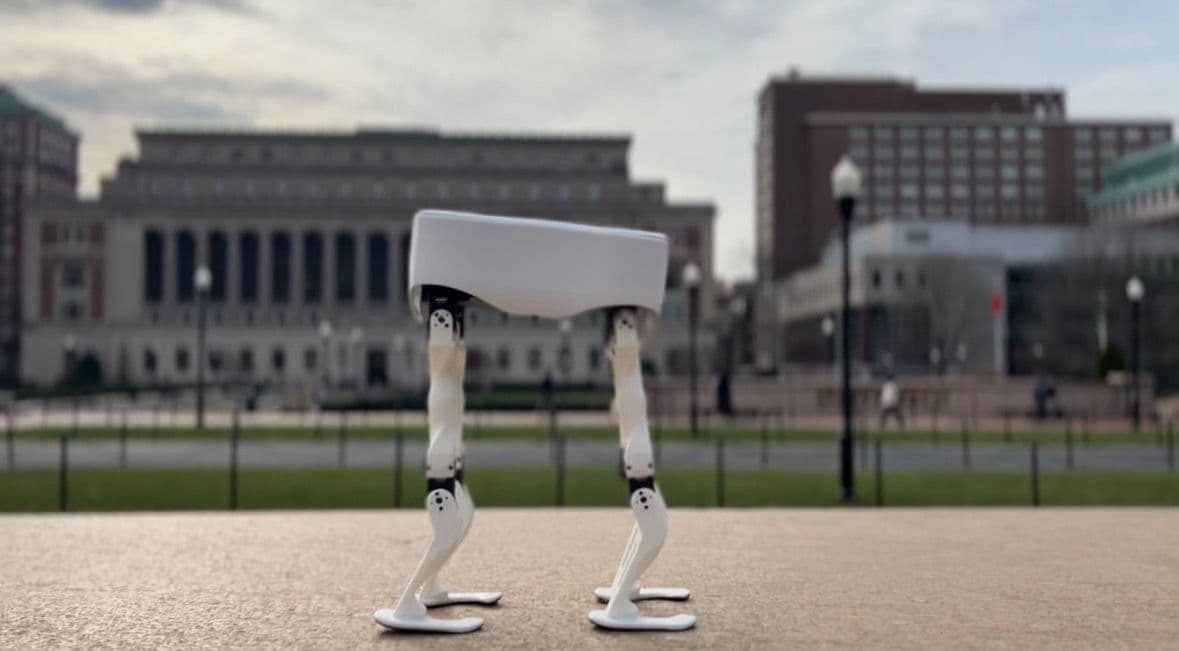
The assembled quadruped walking robot

Quadruped Walking Robot

From CAD to a robot that walks at 25.6 cm/s

A complete end-to-end robotics pipeline: concept, SolidWorks CAD, MuJoCo simulation, 3D-printed fabrication and finally autonomous walking in the real world.

CADSimulationRoboticsEmbedded SystemsPythonPrototypingOOP
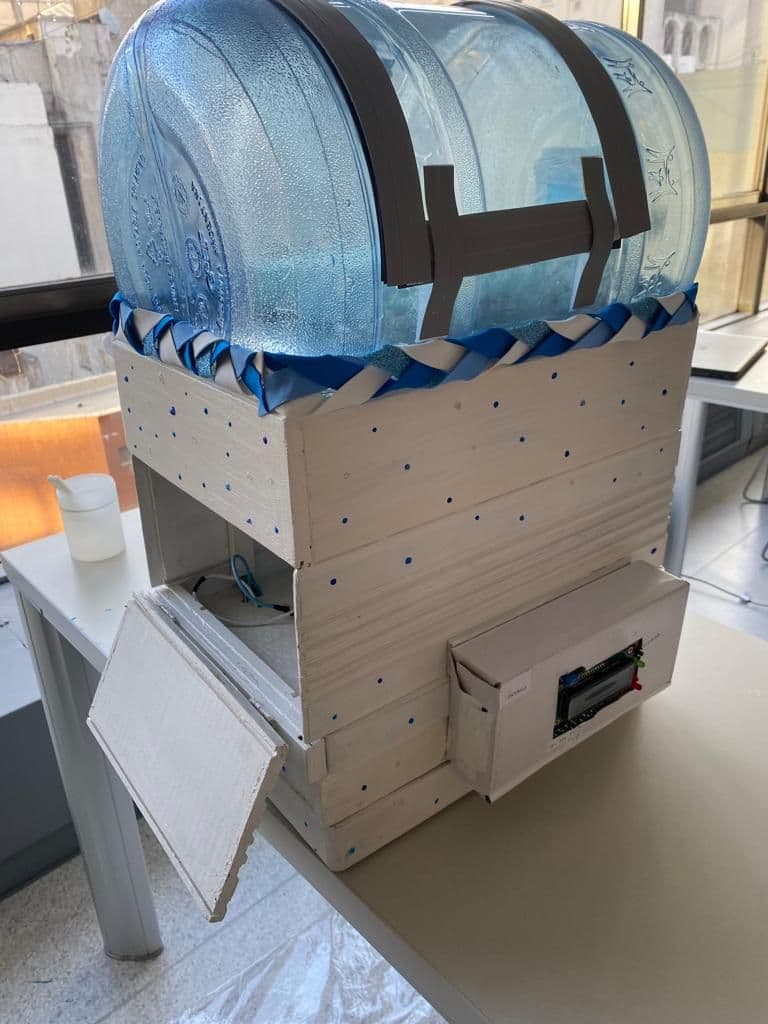
The assembled neonatal incubator prototype

Neonatal Incubator with IoT Monitoring

A low cost incubator built from salvage, held to a certified envelope

A neonatal incubator prototype built from consumer and reclaimed parts, with two closed loop controllers, sensors calibrated against physical references, fail safe alarm logic, and MQTT telemetry that scales one unit into a ward monitoring centre.

ArduinoESP32C++PID ControlSensor CalibrationMQTTThingsBoardIoTEmbedded Systems
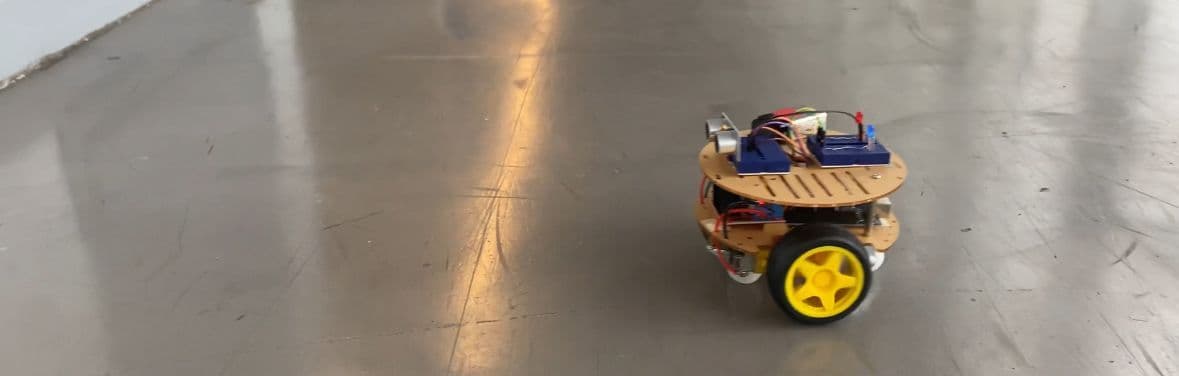
Bioinspired Arduino robot prototype

Bioinspired Robotics

Braitenberg vehicles, and where they stop being vehicles

Six Arduino robots built as physical Braitenberg vehicles: a sensor wired almost straight to a motor, no world model, and in four of the six no memory at all. Includes the honest accounting of which ones are really vehicles and which are finite state machines in disguise.

Braitenberg VehiclesRoboticsC++ArduinoEmbedded SystemsControl

About

Agustina Selser

Decoding signals, then building the hardware that answers them.

I graduated with honors in BS/MS Bioengineering from ITBA (Buenos Aires) and am currently pursuing an MSc in Biomedical Engineering at Columbia University, where I focus on brain-computer interfaces (BCI) and neuroengineering applications.

I completed a four-month research internship at Polytechnique Montréal on a neuroprosthesis project for hand and arm paralysis, and later continued for a year as an external consultant, which solidified my passion for neural interface technologies.

I also worked at the Cognitive Neuroscience Center (CNC) of Universidad de San Andrés, contributing to neuroscience research through signal analysis and data processing, with a particular emphasis on decoding neural signals.

Most recently I spent a summer at Terrace as an AI engineer intern, remote from Buenos Aires, where I was the primary author of an autonomous coding agent in Go: it takes a Linear ticket or a Slack mention, runs a coding agent against the repository inside a durable workflow, and returns a pull request that has already been built, linted, tested, reviewed and pushed through CI. At its peak it was among the company's top three contributors by merged lines of code.

Software & distributed systems

Go and TypeScript services, React and Next.js interfaces, durable workflows, event-driven microservices, Kubernetes, observability and CI/CD.

Machine learning & LLM systems

PyTorch and scikit-learn pipelines, foundation-model embeddings, neural decoding, multi-agent orchestration and retrieval-augmented context.

Neural interfaces

BCI pipelines, neuroprosthetics, biosignal processing and neural decoding.

Robotics & control

CAD to hardware, MuJoCo simulation, gait design, PID control and reinforcement learning.

Embedded & IoT

ESP32 and Arduino firmware in C++, MQTT telemetry, sensor integration and live dashboards.